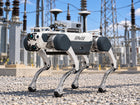
- RTK accuracy of 1 cm + 1 ppm With an RTK fixed solution, horizontal and vertical positioning accuracy is 1.0 cm + 1 ppm (R50).
- Heading from two antennas Dual GNSS-RTK receivers give a heading accuracy of 0.4° on a 1 m antenna baseline.
- Camera and IMU fusion A global-shutter camera with a 120° diagonal view and an IMU feed the sensor-fusion engine alongside the GNSS receivers.
- Four satellite systems It tracks GPS/QZSS, Galileo, BeiDou and GLONASS, each on two signal bands.
- Robot-ready outputs Position is output at up to 100 Hz in NMEA, ROS or Fixposition messages, with RTCM 3 correction input.
- Wide operating range The sensor works from -30 °C to +85 °C and takes its power from the X30.


Leírás
This kit fits the Fixposition VRTK, an RTK GNSS and vision positioning sensor, to the Deep Robotics X30 quadruped. It gives the robot centimeter-level outdoor positioning by fusing two RTK GNSS receivers with a global-shutter camera and an inertial measurement unit, rather than relying on satellite signals alone. It is an accessory; the X30 itself is not included.
It is meant for outdoor routes where the robot has to be in the same place every time: substations, plant yards, pipelines and perimeters patrolled on a schedule. With an RTK fixed solution, horizontal and vertical accuracy is 1.0 cm + 1 ppm (R50), and the two antennas give a heading accuracy of 0.4° on a 1 m baseline. Position, heading and velocity are output at up to 100 Hz in NMEA, ROS or Fixposition's own messages, with RTCM 3 correction input and a cold start under 25 seconds.
The camera and IMU keep the estimate going when satellite reception drops, for example beside tall structures. The drift figure given for a GNSS outage, 0.75% of distance traveled, applies to car mode with a wheel-odometer input; a legged robot provides no wheel odometer, so treat that figure as a reference rather than a promise for the X30.
Among the X30 payloads this is the positioning sensor. Its camera is part of the positioning engine; inspection imagery comes from a separate camera payload, and this kit works alongside one rather than replacing it. The sensor measures 114 × 129 × 30 mm, weighs 420 g, takes a 5-36 VDC supply from the robot and operates from -30 °C to +85 °C. Its typical power draw and the way its position output feeds your navigation software are confirmed with the quotation.
Key Capabilities
- RTK accuracy of 1 cm + 1 ppm: With an RTK fixed solution, horizontal and vertical positioning accuracy is 1.0 cm + 1 ppm (R50).
- Heading from two antennas: Dual GNSS-RTK receivers give a heading accuracy of 0.4° on a 1 m antenna baseline.
- Camera and IMU fusion: A global-shutter camera with a 120° diagonal view and an IMU feed the sensor-fusion engine alongside the GNSS receivers.
- Four satellite systems: It tracks GPS/QZSS, Galileo, BeiDou and GLONASS, each on two signal bands.
- Robot-ready outputs: Position is output at up to 100 Hz in NMEA, ROS or Fixposition messages, with RTCM 3 correction input.
- Wide operating range: The sensor works from -30 °C to +85 °C and takes its power from the X30.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the full manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Jellemzők
Műszaki adatok
| Sensor | Fixposition VRTK |
|---|---|
| Product Type | RTK GNSS + vision positioning kit (accessory) |
| Compatible With | Deep Robotics X30 quadruped |
| Positioning Accuracy (RTK Fixed) | 1.0 cm + 1 ppm R50, horizontal and vertical |
| Heading Accuracy | 0.4° (1 m baseline) |
| Velocity Accuracy | 0.1 m/s |
| Maximum Output Rate | 100 Hz |
| Maximum Speed (Fusion Mode) | 25 m/s |
| Drift During GNSS Outage | 0.75% of distance traveled (car mode with wheel-odometer input) |
| Cold Start | Under 25 s |
| Output Formats | NMEA, ROS, Fixposition custom messages |
| Working Modes | Car, handheld, lawn mower, ground robot |
| RTK Correction Input | RTCM 3 |
| Wheel-Speed Input | UART, Ethernet, CAN |
| GNSS Signals | GPS/QZSS (L1C/A, L2C), Galileo (E1B/C, E5b), BeiDou (B1I, B2I), GLONASS (L1OF, L2OF) |
| GNSS Receivers | Dual GNSS-RTK |
| Camera | Global-shutter CMOS, 120° diagonal field of view |
| IMU | Accelerometer and gyroscope |
| Internal Storage | 16 GB flash |
| Wired Interfaces | 2 × UART, CAN, Ethernet, USB-C |
| Wireless | Wi-Fi 802.11ac/a/b/g/n |
| Antenna Connectors | 2 × SMA (GNSS) |
| Camera Inputs | 2 × MIPI CSI-2 |
| Supply Voltage | 5-36 VDC, powered from the robot |
| Typical Power Consumption | Confirm at quote |
| OEM Board + Camera | 65 × 72 × 17 mm, 49 g |
| Sensor Unit | 114 × 129 × 30 mm, 420 g |
| Operating Temperature | -30 °C to +85 °C |
| Storage Temperature | -40 °C to +85 °C |
Iparágak
Gyakran ismételt kérdések
Precise outdoor positioning and heading. It fuses dual RTK GNSS receivers with a camera and an IMU, reaching 1.0 cm + 1 ppm (R50) with an RTK fixed solution and 0.4° heading on a 1 m baseline.
Yes, for the centimeter figure. An RTK fixed solution needs RTCM 3 corrections from a base station or a correction service, so it is worth deciding which one you will use when you request the quotation.
The camera and IMU keep the position estimate running. The 0.75% drift figure applies to car mode with a wheel-odometer input, so for a legged robot it is a reference rather than a guaranteed value.
It has 2 × UART, CAN, Ethernet and USB-C, Wi-Fi, two SMA antenna connectors and two MIPI CSI-2 camera inputs. It takes a 5-36 VDC supply from the robot; its typical power draw is confirmed with the quotation.
It is compatible with the X30. The X30 Pro is the professional variant of the same robot, and fitment on your unit, alongside any other payloads, is confirmed with the quotation.
The Deep Robotics X30 Fixposition VRTK RTK + Vision Kit is priced at €7.050 in your market.
Legutóbb megtekintett
Még nem tekintett meg egyetlen terméket sem.