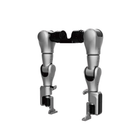
- 10 kg per arm Each seven-axis arm carries a single-arm load of 10 kg, the highest in the Ti5 dual-arm range.
- Fourteen harmonic-drive axes One joint motor per degree of freedom, each with a harmonic reducer and an 18-bit joint encoder.
- 411 N·m strongest joint Maximum single-joint torque is 411 N·m for the strongest axis rather than as a uniform figure for the whole chain.
- 2,013 mm span, 32 kg gross The longest reach and the heaviest build of the three dual-arm models, on a 160 mm maximum arm circumference.
- CAN or EtherCAT control Joint actuators run on CAN or EtherCAT, hands on RS-485 or CAN, with an optional Ethernet interface for the host.
- Optional sensing, compute and power Two six-dimensional force sensors, two RealSense D405 wrist depth cameras, a Jetson Orin Nano 8G upgradeable to an AGX Orin 64G kit and a 48 V 10 Ah battery with a three-hour rating are configurable.
- URDF model before delivery A URDF standard-format structural document is issued after contract signing and before machine delivery, so simulation and motion planning can start early.


Description
The Ti5 A10-1 is a bimanual upper body: two seven-axis arms joined into one fourteen-axis assembly, rated for a 10 kg load per arm, spanning 2,013 mm tip to tip and weighing 32 kg gross. It is built to be integrated rather than switched on — an arm pair that a team mounts to its own torso, base or test rig.
Each degree of freedom has its own joint motor, fourteen in all, every one built around a harmonic reducer and an 18-bit joint encoder. Maximum single-joint torque is 411 N·m, which describes the strongest axis in the chain and not a uniform rating across all fourteen. Joints are commanded over CAN or EtherCAT, hands over RS-485 or CAN, and an Ethernet host interface is available as an option.
Within the Ti5 dual-arm family the A10-1 is the heavy one. Where the A3-0 carries 3 kg per arm and the A5-1 carries 5 kg, the A10-1 carries 10 kg, on the longest span and the thickest arm section of the three at a 160 mm maximum arm circumference. Its standard end effectors are a universal ball clamp and a hook clamp; the dexterous-hand option offered on the lighter models is not part of this model's configuration list.
The rest of the platform is modular. Two six-dimensional force sensors, two Intel RealSense D405 wrist depth cameras, a Jetson Orin Nano 8G computer with an upgrade path to an AGX Orin 64G developer kit and a 48 V 10 Ah battery rated for three hours are all configurable options, so a research group can start with bare arms under its own controller and add sensing later. A URDF structural document is issued after contract signing and before machine delivery.
Key Capabilities
- 10 kg per arm: Each seven-axis arm carries a single-arm load of 10 kg, the highest in the Ti5 dual-arm range.
- Fourteen harmonic-drive axes: One joint motor per degree of freedom, each with a harmonic reducer and an 18-bit joint encoder.
- 411 N·m strongest joint: Maximum single-joint torque is 411 N·m for the strongest axis rather than as a uniform figure for the whole chain.
- 2,013 mm span, 32 kg gross: The longest reach and the heaviest build of the three dual-arm models, on a 160 mm maximum arm circumference.
- CAN or EtherCAT control: Joint actuators run on CAN or EtherCAT, hands on RS-485 or CAN, with an optional Ethernet interface for the host.
- Optional sensing, compute and power: Two six-dimensional force sensors, two RealSense D405 wrist depth cameras, a Jetson Orin Nano 8G upgradeable to an AGX Orin 64G kit and a 48 V 10 Ah battery with a three-hour rating are configurable.
- URDF model before delivery: A URDF standard-format structural document is issued after contract signing and before machine delivery, so simulation and motion planning can start early.
This model is offered on a quotation basis. Configuration, accessories, integration scope and delivery schedule all change the final figure, so pricing is confirmed per project rather than listed.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Ti5 Robotics |
|---|---|
| Model | Ti5-A10-1 Dual-arm Standard Product |
| Product Type | Fourteen-axis dual-arm manipulation platform |
| Total Degrees of Freedom | 14 |
| Degrees of Freedom per Arm | 7 |
| Single-Arm Load | 10 kg |
| Arm Span | 2,013 mm |
| Maximum Arm Circumference | 160 mm |
| Gross Weight | 32 kg |
| Structural Layout | Internal structural components |
| Joint Motors | 14 |
| Maximum Joint Torque | 411 N·m (strongest single joint) |
| Joint Reducer | Harmonic |
| Joint Encoder Resolution | 18-bit |
| Joint Actuator Interface | CAN / EtherCAT |
| Communication Protocols | Joint CAN or EtherCAT; hand RS-485 or CAN |
| Host Interface | Ethernet (optional) |
| Standard End Effectors | Universal ball clamp / hook clamp |
| Force Sensing (optional) | Two six-dimensional force sensors, model M3552D1 with M8123B2.232 interface |
| Vision (optional) | Two Intel RealSense D405 wrist depth cameras |
| Computing (optional) | Jetson Orin Nano 8G, upgradeable to Jetson AGX Orin 64G Developer Kit |
| Battery (optional) | 48 V 10 Ah, 3 h rated battery life |
| Structural Materials | Aluminium alloy, stainless steel |
| Shell Materials | Aluminium alloy, ABS with glass fibre, rubber |
| Documentation | URDF standard-format structural document, issued after contract signing and before machine delivery |
| Dexterous Hand Option | Confirm at quote |
| Price | Quotation only |
Industries
Frequently Asked Questions
Fourteen in total, seven per arm, driven by fourteen joint motors with harmonic reducers and 18-bit joint encoders.
Payload and scale. The A10-1 carries 10 kg per arm against 5 kg on the A5-1 and 3 kg on the A3-0, with a 2,013 mm span, a 160 mm maximum arm circumference and a 32 kg gross weight. Its standard end effectors are ball and hook clamps rather than the dexterous hand offered for the lighter models.
Joint actuators communicate over CAN or EtherCAT and hands over RS-485 or CAN. An Ethernet interface for the host controller is available as an option.
No. The two six-dimensional force sensors, two Intel RealSense D405 wrist depth cameras, the Jetson Orin Nano 8G compute module with its AGX Orin 64G upgrade path and the 48 V 10 Ah battery are all configurable options and have to be specified when ordering.
Yes. A URDF standard-format structural document is issued after contract signing and before machine delivery, which is what simulation and motion-planning toolchains need.
It is offered by quotation — configuration, quantity and delivery are confirmed per project, and the price is set in the quotation.
Recently Viewed
You haven't viewed any products yet.