- One Base, Three Mobility Roles It combines AGV-style indoor precision, vehicle-type off-road range and legged terrain traversal in one platform.
- Unified Control Framework Galileo's Unified Embodied Ground Mobility System coordinates mechanics, actuation, perception and control.
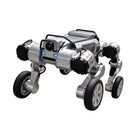
- Wheels on Articulated Legs Its four articulated legs end in wheels, pairing wheeled travel with legged terrain traversal.
- Chassis for Humanoids It is intended as a mobile base for humanoid robots as well as for transport and inspection payloads.
- Open Interfaces Planned Galileo plans to open core hardware and software interfaces to developers and industry partners.
- Newly Unveiled It was introduced at the 2026 World Robot Conference; specifications and supply terms are confirmed at quote.

Description
Galileo X is a newly unveiled platform: Galileo Robotics introduced it at the 2026 World Robot Conference in Beijing, and its technical specifications have not yet been released. Galileo calls it an Embodied Ground Mobility System, meant to remove the usual split between wheeled AGVs, off-road vehicle platforms and legged robots.
The idea is one robotic base for three kinds of work: the precise indoor movement expected of an automated guided vehicle, the long-range outdoor travel of a vehicle-type platform, and the complex-terrain traversal of a quadruped. It stands on four articulated legs that end in wheels, and runs on Galileo's Unified Embodied Ground Mobility System, which coordinates mechanics, actuation, perception and control under one control framework.
That makes it a different proposition from Galileo's C1-W, E1-W and S1-W wheeled quadrupeds, which are fully specified models for inspection, patrol and field work. Galileo X is positioned as a foundation for heavy-duty off-road handling, warehouse logistics and directional transfer, inspection and perception payloads, mobile operation platforms, and as a mobile chassis for humanoid robots. Galileo plans to open its core hardware and software interfaces so that algorithm developers, application providers and industry partners can build on it.
Payload, speed, weight, dimensions, runtime and protection rating have not been released, and we do not estimate them. They are confirmed in writing, together with configuration and terms of supply, before any order.
Key Capabilities
- One Base, Three Mobility Roles: It combines AGV-style indoor precision, vehicle-type off-road range and legged terrain traversal in one platform.
- Unified Control Framework: Galileo's Unified Embodied Ground Mobility System coordinates mechanics, actuation, perception and control.
- Wheels on Articulated Legs: Its four articulated legs end in wheels, pairing wheeled travel with legged terrain traversal.
- Chassis for Humanoids: It is intended as a mobile base for humanoid robots as well as for transport and inspection payloads.
- Open Interfaces Planned: Galileo plans to open core hardware and software interfaces to developers and industry partners.
- Newly Unveiled: It was introduced at the 2026 World Robot Conference; specifications and supply terms are confirmed at quote.
This model is offered on a quotation basis. Configuration, accessories, integration scope and delivery schedule all change the final figure, so pricing is confirmed per project rather than listed.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the full manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Galileo |
|---|---|
| Manufacturer | Galileo Robotics |
| Model | Galileo X |
| Product Type | General-purpose ground mobility platform (Embodied Ground Mobility System) |
| Layout | Four articulated legs ending in wheels |
| Control Architecture | Unified Embodied Ground Mobility System: integrated hardware with a unified control framework |
| Mobility Roles | AGV-style indoor transport, long-range off-road travel, complex-terrain traversal |
| Intended Applications | Heavy-duty off-road handling; warehouse logistics and directional transfer; inspection and perception; mobile operation platforms; humanoid robot chassis |
| Developer Access | Core hardware and software interfaces planned to open to developers and partners |
| Unveiled | 2026 World Robot Conference, Beijing |
| Payload | Confirm at quote |
| Speed | Confirm at quote |
| Weight | Confirm at quote |
| Dimensions | Confirm at quote |
| Runtime | Confirm at quote |
| Ingress Protection | Confirm at quote |
| Pricing | Quotation only |
Industries
Frequently Asked Questions
A general-purpose ground mobility platform that Galileo unveiled at the 2026 World Robot Conference in Beijing. It is designed to combine the indoor precision of a wheeled AGV, the outdoor range of an off-road vehicle platform and the terrain traversal of a legged robot.
Those are fully specified wheeled quadrupeds for inspection, patrol and field work. Galileo X is a new platform intended as a foundation for several applications, including a mobile chassis for humanoid robots, and its specifications have not yet been released.
Galileo has not yet released technical specifications for Galileo X. We do not estimate them; they are confirmed in writing before you order.
Heavy-duty off-road handling, warehouse logistics and directional transfer, inspection and perception payloads, mobile operation platforms, and as a mobile chassis for humanoid robots.
Galileo plans to open core hardware and software interfaces around Galileo X so that algorithm developers, application providers and industry partners can build integrated solutions. The interfaces available on a given unit are confirmed at quote.
It is offered by quotation — configuration, quantity and delivery are confirmed per project.
Recently Viewed
You haven't viewed any products yet.